ESP-FC
Flight controller firmware for quadcopters on a plain ESP32, set up from the Betaflight Configurator.
Chipnik catalog@chipnik-catalogWhat you need
- Board
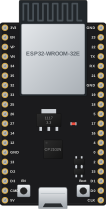
- One of 2 boards: ESP32 DevKit, ESP32-S3 DevKit
- Parts
- Gyro module MPU6050, MPU6500 or ICM42688, Quadcopter frame with 4 motors and ESCs, RC receiver
ESP-FC is a flight controller for multirotors that runs on an ESP32 or ESP32-S3. It reads a gyro over SPI or I2C, mixes the motors over DShot or PWM, takes RC input from SBUS, CRSF or IBUS and even ESP-NOW, and talks the Betaflight protocol, so you tune it in the familiar Betaflight Configurator. Original project by rtlopez on GitHub, MIT. Chipnik hosts the release binaries unchanged so you can flash them from the browser.
You build the drone yourself: frame, motors, ESCs, an MPU6050 or ICM42688 gyro and a receiver. The pin map for each chip is in the project README. Test with the propellers removed first.
Firmware files come from the v0.2.1 release.
Parts
Buy everything for this project
- ESP32 DevKitC (WROOM-32)BuyAliExpress
- ESP32-S3 DevKitC N16R8BuyAliExpress
- 1 × Gyro module MPU6050, MPU6500 or ICM42688BuyAliExpress
After flashing
- The board restarts by itself when flashing is done.
- If nothing happens, press the RST (EN) button once.
Versions
0.2.1 added to Chipnik 2026-11-05
Release v0.2.1 of rtlopez/esp-fc, files unchanged. Release notes on GitHub